ASENA FLIGHT RECORDER
Real robot data
One recording. Synchronized signals.
MCAP
deck-20260908-175129.mcapBag time 579.00 s · 579–589 s excerptWhat the robot saw
360° camera · ≈ 2 Hz/camera/rgb360
Measured left knee0.139 rad
How its body moved
29 joints + base pose · 20 Hz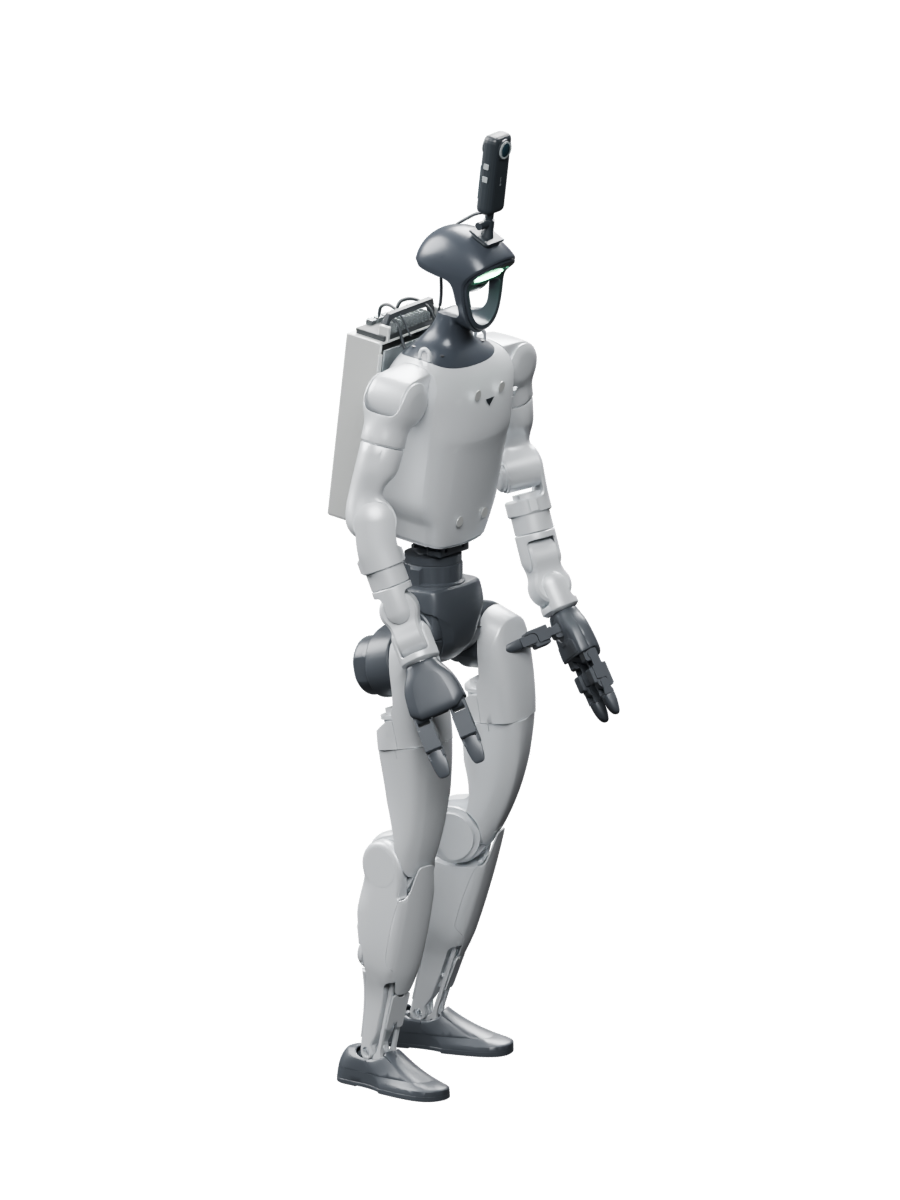 Static preview · load replay with Play
Base displacement0.000 m
Relative yaw0.0°
State sample000 / 200
Press Play or scrub to load the 3D model. Camera and body share the recorded clock.
Inspect this recorded state sample 29 joint angles, pose, timestamp
The replay interpolates between measured states. This is the nearest exported 20 Hz sample; positions use the recording’s coordinates, before the display’s axis conversion.
{
  "bag_time_s": 579.0,
  "clip_time_s": 0.0,
  "sample_index": 0,
  "q29_rad": [
    0.122071,
    0.100229,
    0.265475,
    0.138638,
    -0.219354,
    -0.028817,
    -0.025865,
    -0.007926,
    -0.157328,
    0.194483,
    -0.16011,
    -0.014144,
    0.007794,
    0.024403,
    0.139196,
    -0.027935,
    0.27354,
    -0.606054,
    1.044976,
    -0.083686,
    -0.170763,
    0.117661,
    -0.025347,
    -0.296166,
    0.583212,
    0.979483,
    0.129609,
    -0.065086,
    -0.27662
  ],
  "root_position_m": [
    0,
    0,
    0.732141
  ],
  "root_quaternion_wxyz": [
    0.999956,
    -0.008018,
    -0.004899,
    -3.9e-05
  ],
  "odometry_position_m": [
    1.186216,
    -0.250574,
    0.732141
  ],
  "odometry_yaw_rad": -0.372653
}